GOLDRIVERBOT / AUTONOMOUS RIVER SURVEY

A field robot for the places maps miss.

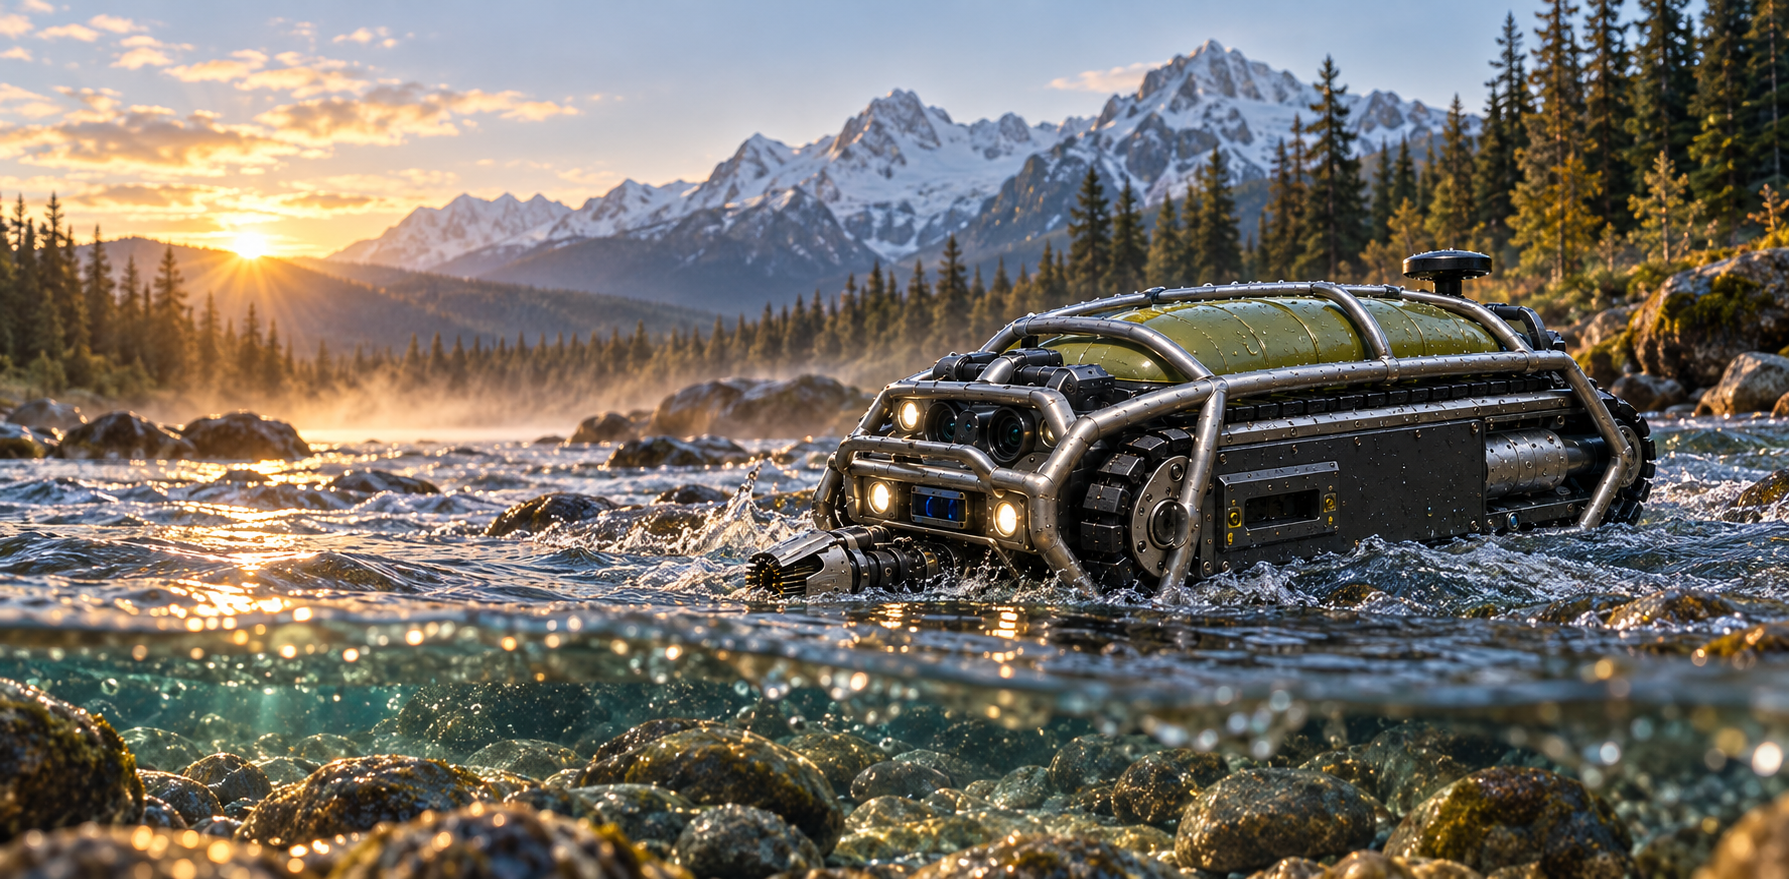
GoldRiverBot is a preliminary concept for a tracked, instrumented river crawler that surveys alluvial bends, records geological context, and returns a traceable concentrate sample. It is a design study—not a proven commercial product.

GoldRiverBot concept illustration

From reconnaissance to evidence

Aerial context, underwater perception, pulsed-induction experiments, and disciplined sampling are joined into one field workflow. Every gold result is treated as a hypothesis until blanks, standards, and laboratory assays agree.

  • Deploy from a bank, boat, or helicopter-supported field camp.
  • Keep a synchronized map of track, depth, turbidity, sensor readings, and retained concentrate.
  • Design for retrieval and inspection when conditions exceed the envelope.
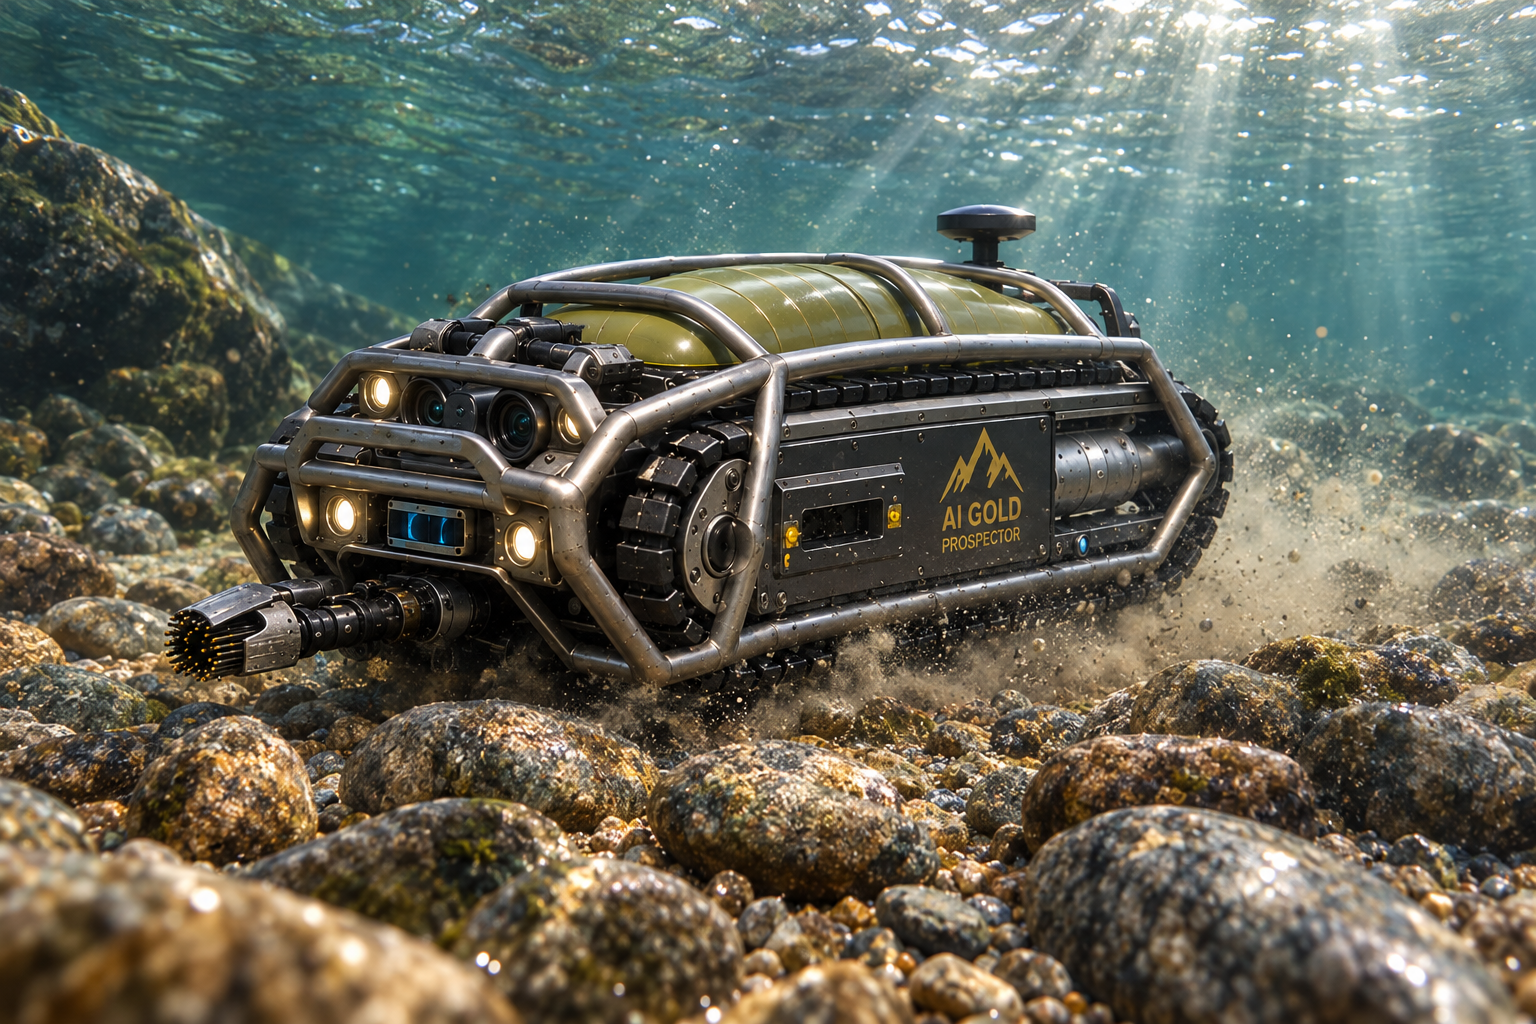
From reconnaissance to evidence

Explore the design

The routes below describe the mechanical platform, sensor stack, sampling path, autonomy, energy budget, and field procedures in engineering language.

Jarvis generated email flow verified — October 17, 2026.