07 / ROADMAP

Prototype roadmap

The concept becomes credible one controlled test at a time.

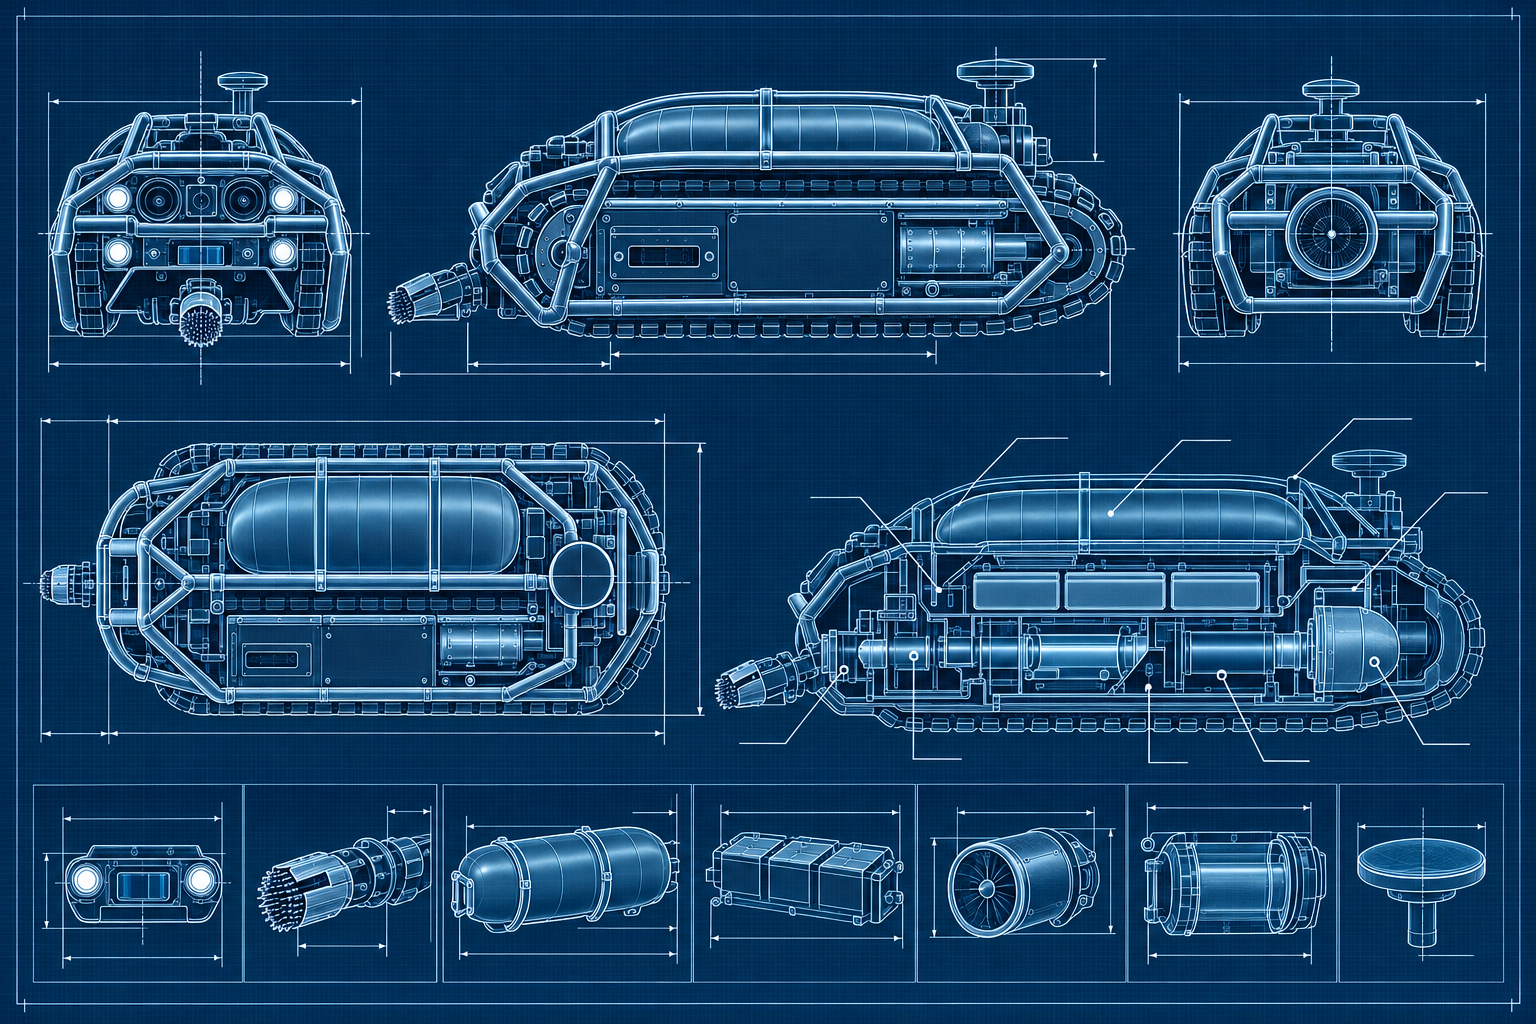
GoldRiverBot concept illustration

Phase 1 — prove the interfaces

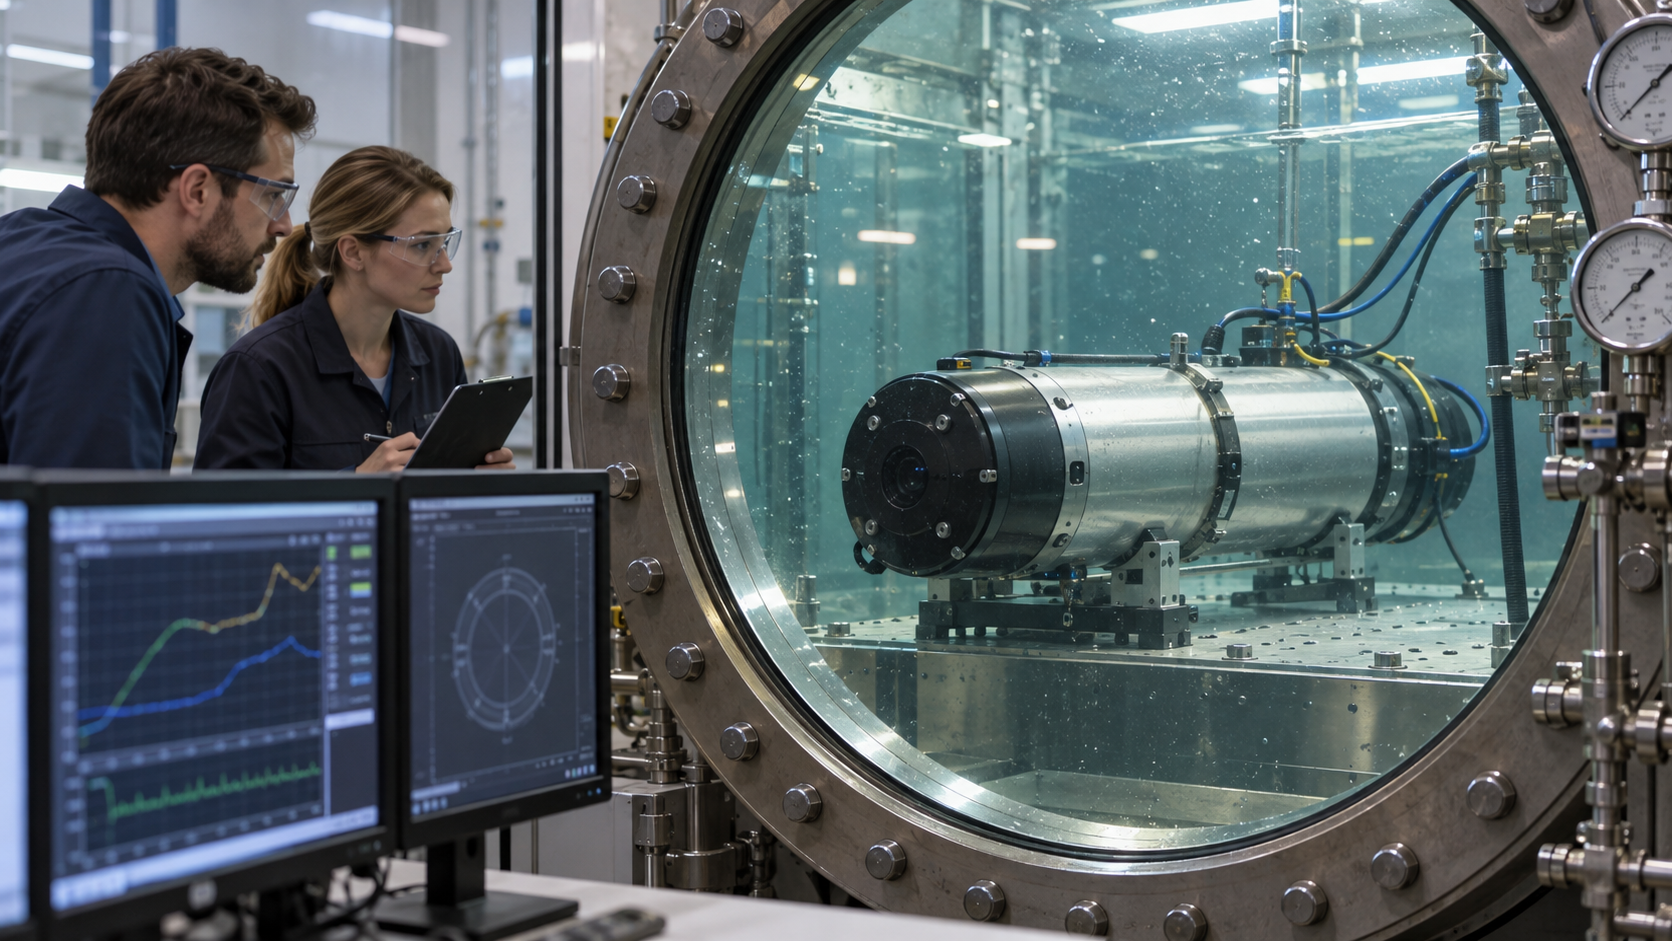
Build the pressure hull, track pods, bladder cells, sample bay, and buoy as separate test articles. Exercise seals, connectors, current limits, and retrieval points on the bench.

  • Pressure and leak test
  • Seeded gravel separation test
  • PI calibration on known conductors
  • Camera and sonar synchronization
Phase 1 — prove the interfaces

Phase 2 — clear-water pilot

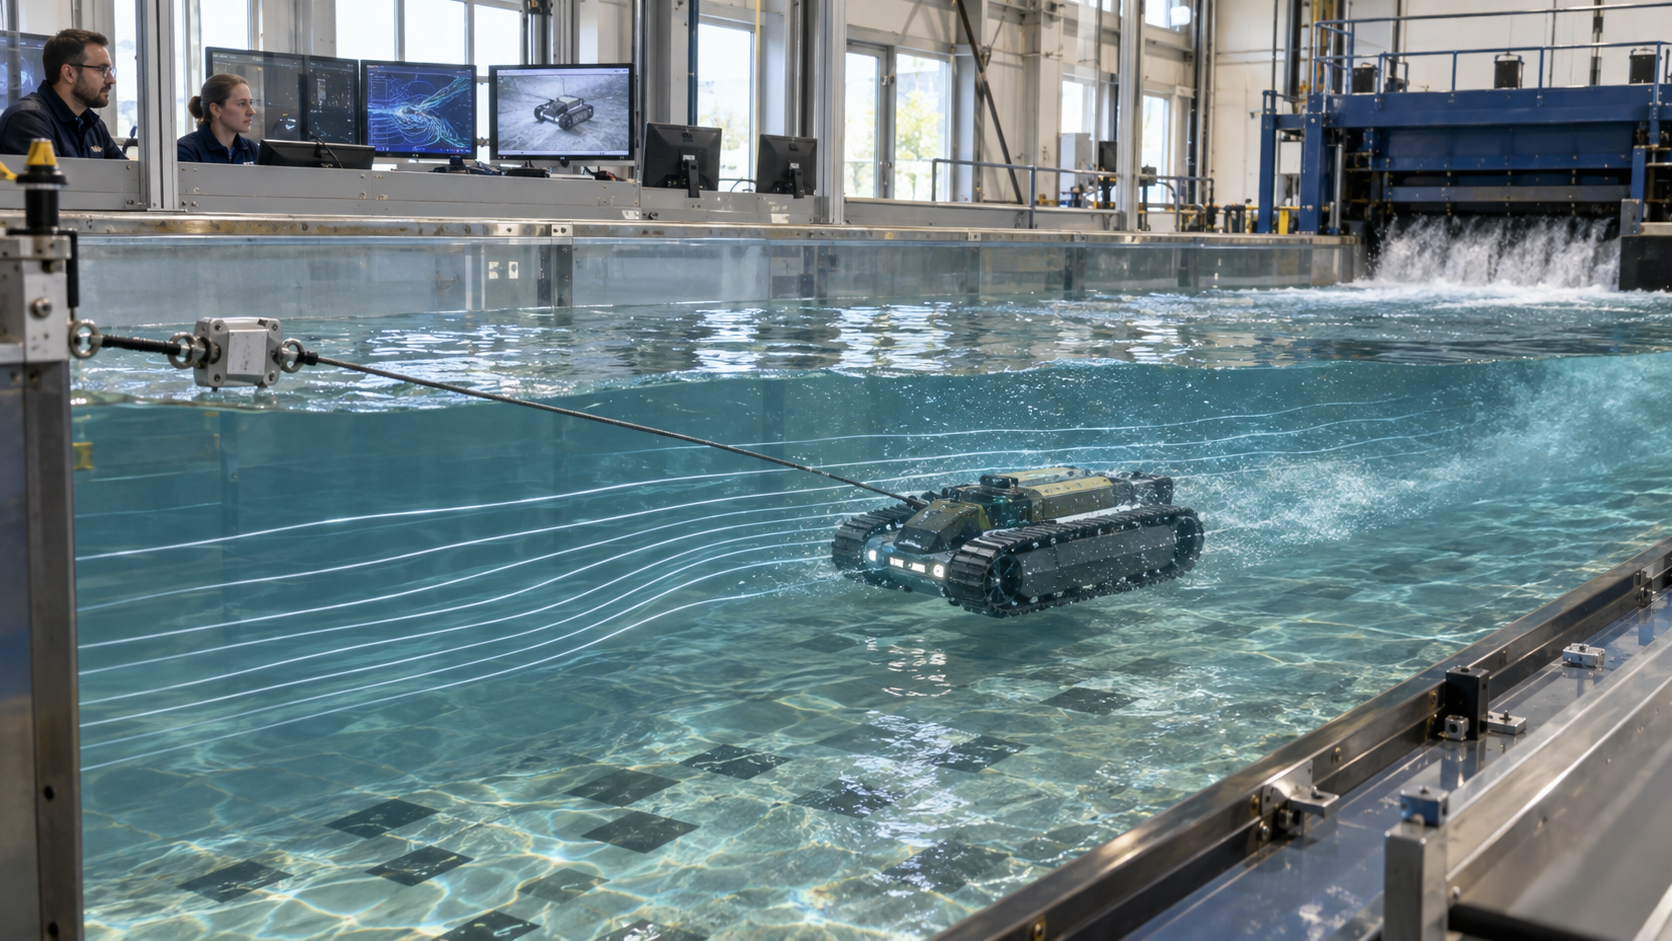
Run supervised tank and calm-water missions with no environmental claims. Compare stereo, sonar, and conditional green-LiDAR returns, and quantify false PI alerts.

Phase 2 — clear-water pilot

Phase 3 — permitted river pilot

Move to a permitted site with a written recovery plan. Compare retained cartridges against blanks and laboratory assays, then publish limitations alongside any exciting result.

What success looks like

Success is not a generated image of a nugget. It is repeatable localization, a known false-alert rate, safe recovery after simulated failures, a measured separation efficiency on seeded material, and a sample record another investigator can audit. The first release should publish its negative results and the conditions under which each sensor becomes unreliable.

  • Repeatable target localization
  • Measured recovery efficiency
  • Documented optical/sonar/PI failure modes
  • Independent assay comparison
  • A safe, recoverable abort path